TEST COURSE
Same robot, same map. One of them is lost.
Re-enacted from two real Nav2 runs on 18 October 2026. In run B, AMCL listens on /lidar/scan while the lidar publishes /scan, so the robot never gets a map pose. FlightOps puts both runs side by side and writes down the difference.
SCENE WORKBENCH
Two runs. One cursor. The difference in writing.
A native desktop app that draws what the recordings show. Here, a healthy Nav2 run sits beside one where AMCL listens on the wrong lidar topic and the robot never gets a map pose.
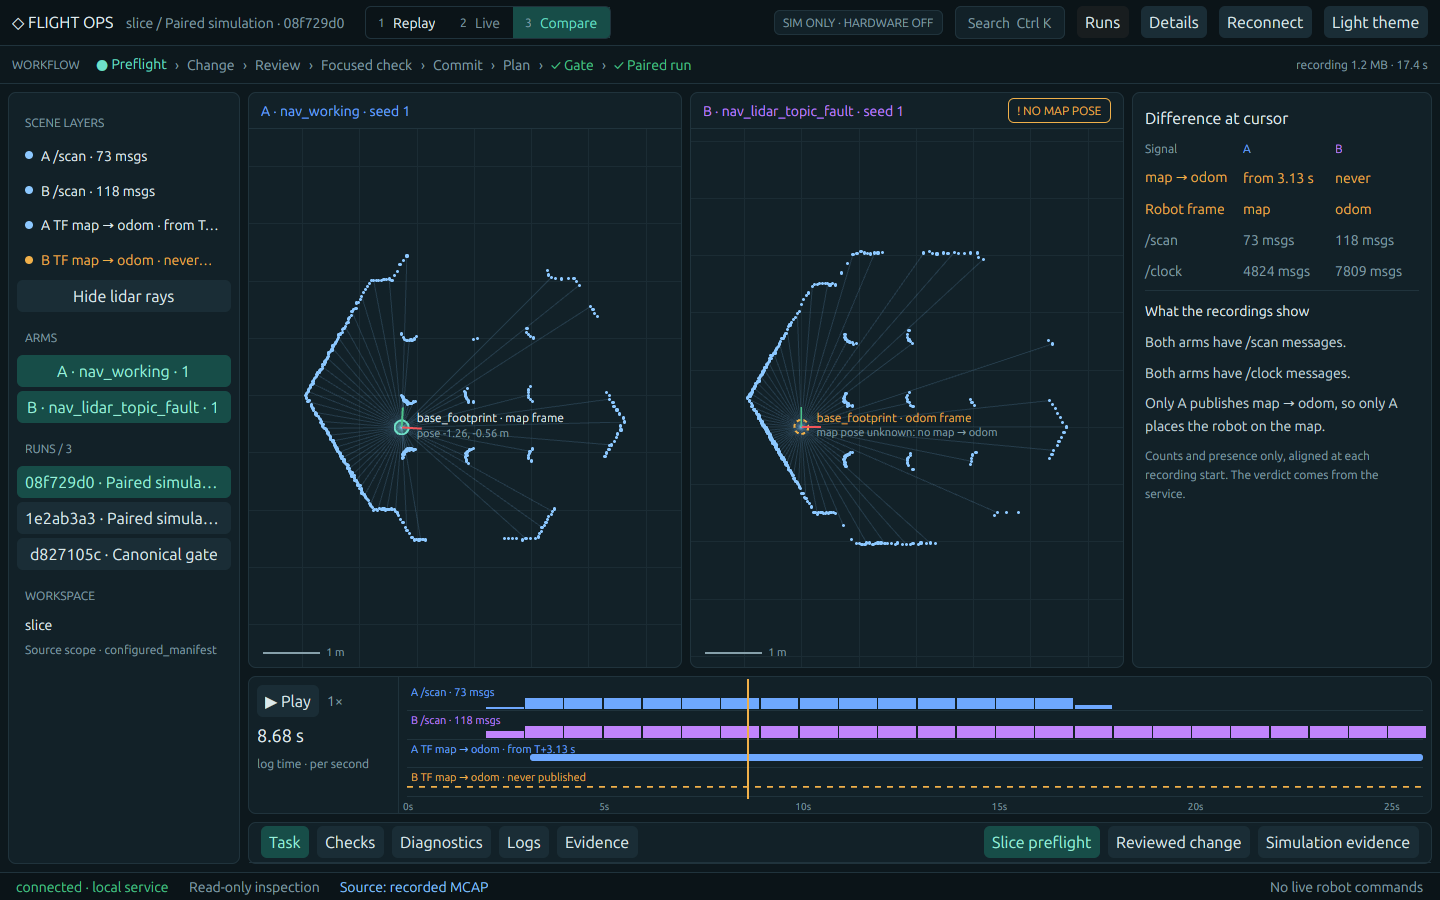
The fault, flagged. Run B never gets a map pose, and the app says so instead of drawing a guess.
Difference at cursor. map → odom from 3.13 s in A, never in B. Every differing signal, listed.
One timeline. Every topic, every gap, one cursor. Play, scrub or jump to a message.
Read-only by design. Simulation only, hardware off. No live robot commands, ever.
NEXT DRAWER